Transactions on SMC: Systems

Scope

The scope of the IEEE Transactions on Systems, Man, and Cybernetics: Systems includes the field of systems engineering. It also includes issue formulation, analysis and modeling, decision making, and issue interpretation for any of the systems engineering lifecycle phases associated with the definition, development, and deployment of large systems. Other topics include systems management, systems engineering processes, and a variety of systems engineering methods such as optimization, modeling and simulation.

IEEE Transactions on Systems, Man, and Cybernetics Part A: Systems and Humans was renamed IEEE Transactions on Systems, Man, and Cybernetics: Systems on January 1, 2013.

Posting Preprints to Non-IEEE Servers

Authors should disclose postings on approved preprint services when submitting papers to SMCS Journals.

Consult relevant sections posted here.

The following statement must be included on the initial screen of the preprint site:

“This work has been submitted to the IEEE for possible publication. Copyright may be transferred without notice, after which this version may no longer be accessible.”

Upon acceptance of the article by IEEE, the preprint article must be replaced with the accepted version, as described in the section “Accepted article.”

Editor-in-Chief
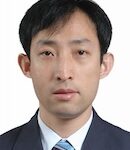
Huijun Gao

Editor-In-Chief
Harbin Institute of Technology
Research Institute of Intelligent Control and Systems
Harbin, 150001, China

Articles

30 October 2026
published version [1], Lemma 6 was mistakenly replaced with content identical to Lemma 7. Upon verification, Lemma 6 should read as follows: “For a given constant $varepsilongt 0$ and any $xinmathbb{R}$ , it holds that $0leq |x|-(x^{2}/sqrt{x^{2}+varepsilon^{2}})lt varepsilon$ .”...
30 October 2026
null...
30 October 2026
null...
See more at IEEE Xplore

09 September 2026
This article investigates the resilient control problem for nonlinear multiagent systems (MASs) under false data injection (FDI) attacks on both sensors and actuators. To enhance the operational resilience and coordination reliability of networked cyber–physical systems under such attacks, a resilient control framework is developed based on a robust selection mechanism...
01 September 2026
A model-free robust fuzzy tracking strategy for autonomous vehicles (AVs) is developed by integrating hybrid reinforcement learning (RL) with a zero-sum game framework. First, the vehicle dynamics are modeled by the Takagi–Sugeno fuzzy technique while simultaneously accounting for velocity variations and external disturbances. The tracking objective is then formulated as...
24 August 2026
This study addresses the predefined-time event-triggered practical output leader-follower consensus problem in high-order strict-feedback nonlinear multiagent systems (MASs) with unknown dynamics, subjected to a false data injection attack (FDIA), over a digraph. This problem introduces fundamental challenges, including estimating the leader’s states, achieving predefined-time consensus tracking under unreliable information due...
19 August 2026
This article proposes a fixed-time fault-tolerant control (FTFTC) method for attitude tracking of rigid spacecraft subject to actuator faults, input saturation, and asymmetric full-state prescribed performance (AFSPP) constraints. First, a fixed-time sliding-mode disturbance observer (SMDO) with dynamic gains is developed to estimate the lumped perturbations in the spacecraft attitude dynamics....
28 July 2026
The multiagent pursuit-evasion game (PEG) with obstacle avoidance remains a challenging cooperative-competitive problem. A key difficulty is achieving effective cooperation and obstacle avoidance in nonstationary environments. Previous studies typically assume that agents can automatically obtain accurate obstacle position information within a certain range, while overlooking the role of sensors in...

See more at IEEE Xplore